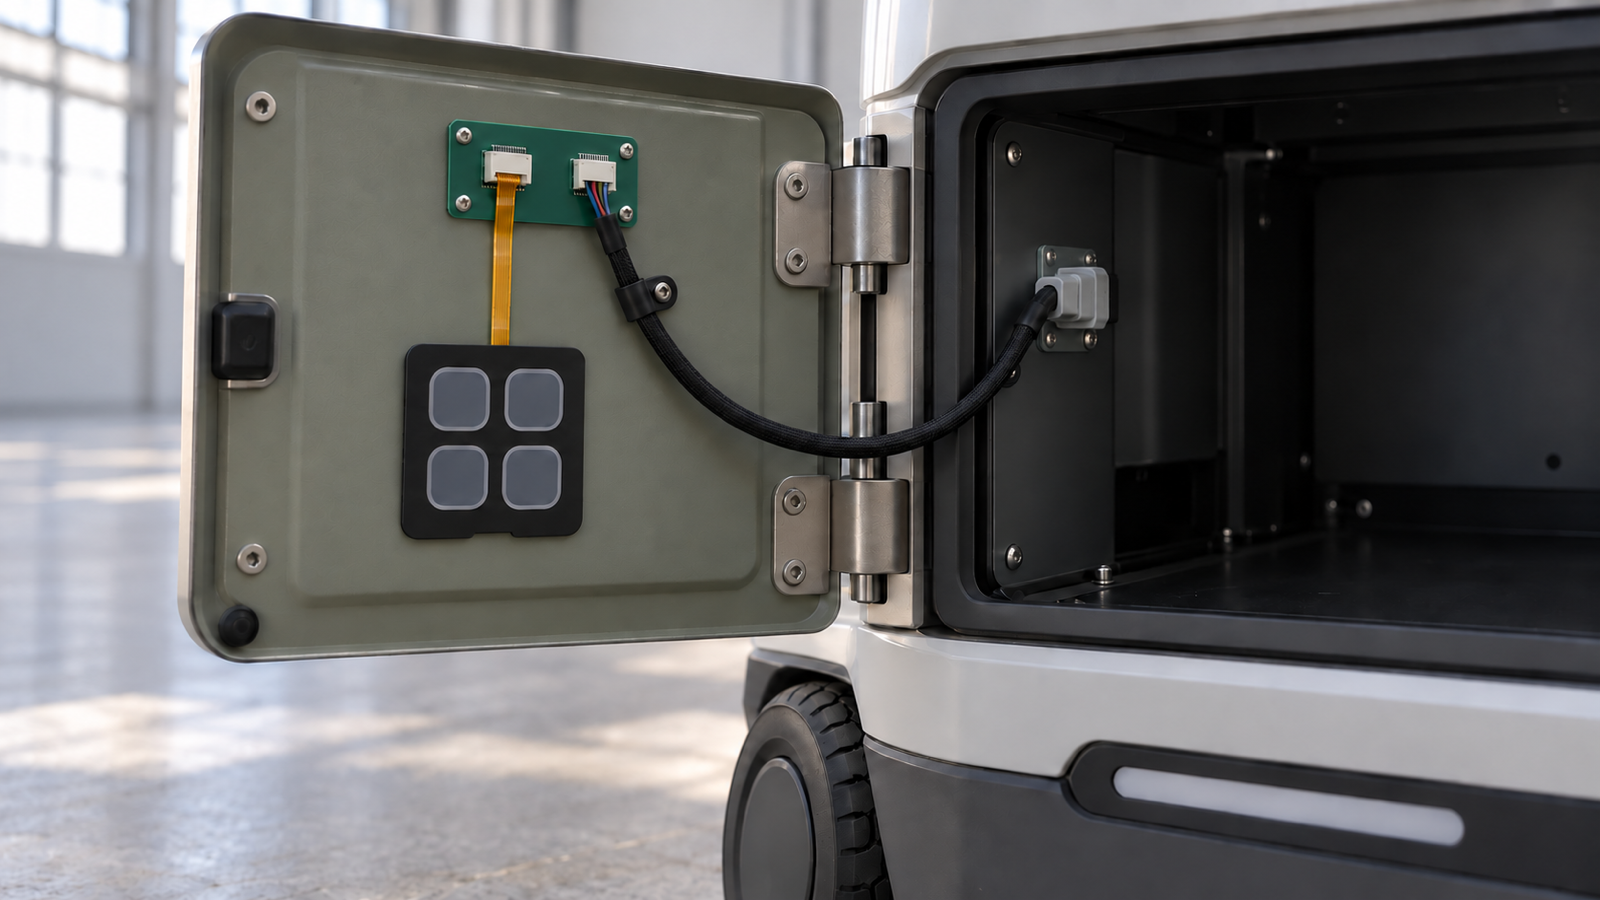
For a delivery robot with a keypad on a hinged service hatch, do not treat a flexible tail as permission for repeated hinge movement. A useful starting arrangement is to terminate the keypad's FPC on electronics mounted to the same hatch, then carry the moving connection through a separately specified service harness. That separates keypad packaging from the hinge-motion duty. A continuous FPC across the hinge is another option only when its construction and installed motion have been designed and qualified for that duty. Choose the motion boundary first; adding tail length alone does not resolve the decision.
Fleet support makes the service hatch an interface requirement
On September 11, 2026, Stellantis Pro One and UQI Robotics announced plans to explore an autonomous last-mile logistics concept. The announcement describes a European initial focus and a planned September 14 public presentation of Box-on-Wheels. At this article's publication, that presentation is still ahead. This is a concept and validation programme, not evidence that a particular service keypad has entered production.
The release also discusses services, connectivity and fleet integration around the vehicle. For robot equipment teams, that wider support requirement creates a practical design question: how will someone reach the internal controls and electronics without disturbing the keypad connection? The source does not disclose the concept's hatch, keypad or circuit design. The arrangement discussed here is a generic option for an OEM that chooses a hatch-mounted service interface, not a description of the announced vehicle.
A service opening deserves its own movement requirement even if recipients never see that interface. A connection that works with the door closed can still be stretched, rubbed or sharply folded while the hatch is opened. Those intermediate positions belong in the equipment design review.
Put the motion boundary on the assembly drawing
Mark which parts move together. If the keypad, its tail support and its mating board are all on the hatch, their relative positions can remain fixed while the hatch swings. The cable connecting that board to the robot body must then accommodate the movement. If the keypad is on the hatch but its FPC connector is on the body, the flexible circuit itself crosses the moving boundary.
These are different mechanical duties, even with the same number of keys and electrical contacts. A bend used to install a tail is not automatically a bend suitable for repeated opening. Minco's flex-circuit design FAQ distinguishes installation bends from rolling or dynamic bends and identifies construction, bend count and bend angle as relevant factors. Its guidance is useful background, not a motion rating for another supplier's keypad.
Include the fully open position, normal access position and closed position on the route drawing. Then identify the path between them. A neat-looking loop at either endpoint can still pass through a pinch point during movement. Review the hinge, door stop, board edge, latch and nearby wiring as one assembly rather than asking the keypad supplier to approve an isolated tail photograph.
A door-mounted termination changes the tradeoff
A local termination can keep the keypad tail out of the moving span. It also adds something: board space, another connector or an interconnection assembly that needs fixing and documentation. This arrangement is useful when separating the keypad from a replaceable moving harness simplifies the design. It is not automatically smaller or cheaper.
A continuous dynamic FPC may reduce separate connectors and fit a restricted space. However, the entire flexing section must be specified for the real motion, including its stack, supports, available bend envelope and connection transitions. The word FPC on a quotation does not establish a qualified flex life. Neither does a flat continuity test.
Use the table to choose the architecture before finalizing a tail drawing. It compares review obligations, not measured performance or a universal winner.
| Arrangement | What moves at the hinge | Why a team might choose it | What still needs evidence |
|---|---|---|---|
| Keypad tail terminates on a hatch-mounted board; separate harness reaches the body | The harness between supported endpoints | Separates keypad packaging from a replaceable moving connection | Harness motion suitability, clearance, connector retention and service access |
| Keypad FPC continues directly to a body-mounted board | A defined section of the FPC | Fewer separate interconnections where the enclosure permits a controlled route | Dynamic construction review, bend envelope and installed movement qualification |
| Keypad and electronics stay on a fixed body section | No keypad connection crosses the hatch hinge | Removes hatch movement from this interface | Whether a technician can actually reach and operate the fixed controls |
| Removable panel is disconnected before removal | A connector is handled during service, rather than flexing through a hinge cycle | Makes removal a defined service operation | Disconnect procedure, connector access, handling protection and mating duty |
Keep strain support separate from electrical mating. A connector should not become the stop that limits hatch opening. Any clamp or support also needs to avoid transferring a sharp bend into the tail edge or stiffener transition. For a moving harness, extra slack without a controlled path may exchange tension for snagging.
Test the open-to-closed journey, not only the end positions
Use an unpowered representative enclosure first to inspect the route through the complete permitted movement. Check whether the tail or harness changes curvature as intended, touches an edge, rubs another part or becomes trapped near the latch. Repeat the inspection with the actual supports and connector access geometry, not a loose cable held temporarily by hand.
The next step is an agreed functional and movement test on the representative assembly. Define which circuits are monitored, the allowed operating positions, the motion sequence and the pass/fail criteria. A reading taken only after movement can miss an intermittent connection during movement. The OEM must specify the service duty and decide the required sample quantity and qualification conditions; no generic cycle count is offered here.
Record any deviation against the route drawing. If a clamp position changes to solve interference, that is a controlled assembly change, not an undocumented adjustment to the demonstration sample. The approved route should be possible to reproduce in production without an assembler inventing a different fold each time.
Choose a scope the keypad supplier can actually review
Baoshengda's FPC membrane switches with defined tail and connector interfaces provide a component route for compact keypad layouts, contact-finger geometry, tail exits and mounting review. Send the chosen architecture with the keypad request so static installation, occasional service handling and repeated motion are not treated as the same requirement.
A useful drawing and sample package contains:
- The keypad outline, control layout and electrical pin map, with the mating connector model and contact orientation.
- A hatch-and-body sketch showing which board carries the tail connector, the hinge axis and the open-to-closed route.
- The supported tail region, stiffener transition and available clearance, plus a separate moving-harness scope when applicable.
- The expected access operation, any disconnect step and the buyer's required movement and functional acceptance evidence.
- Representative mounting parts, prototype quantities and production quantities, with unresolved items marked for review.
Baoshengda can review the proposed keypad construction, tail and connector inputs and discuss the sample evidence required. This does not establish a dynamic-life rating without the relevant design and test work. The robot OEM remains responsible for the harness specification, hinge mechanics, access controls, electrical protection and whole-machine qualification. A membrane service key is not, by itself, a safety-rated stop or access interlock.
Request a keypad integration review with one annotated sketch showing where the stationary keypad connection ends and the moving connection begins. If the architecture is undecided, send both routes and the space constraint. That lets the first discussion resolve the motion boundary rather than price two incompatible assumptions about one long tail.
Need help reviewing a structure?
Send your drawing, photos, application, and quantity. Baoshengda can help check the structure before sampling.
Send Drawing for Quote